What it does
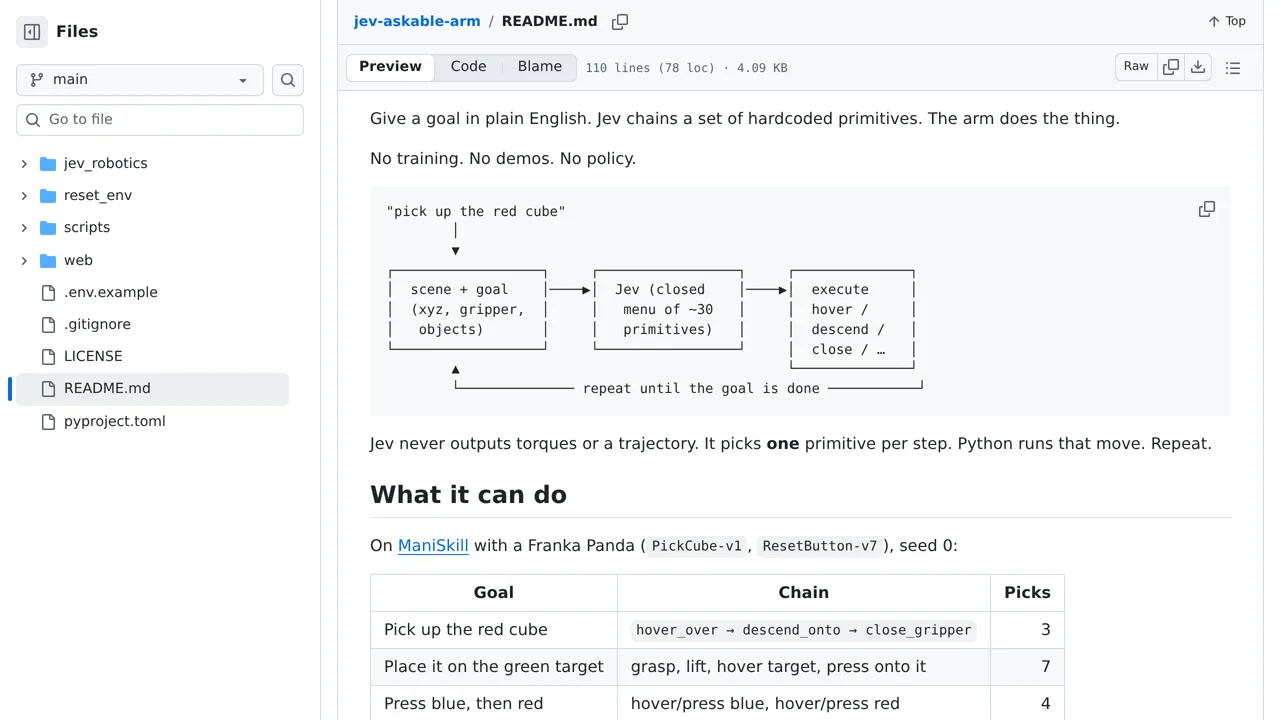
Jev turns plain-English goals into sequences of hardcoded actions for a simulated Franka arm.
Playable demos & bots
Only you can see your notes.
Screenshot unavailable. Open the experiment ↗
Jev turns plain-English goals into sequences of hardcoded actions for a simulated Franka arm.
To try this idea, list the simple moves your digital robot arm can do, like closing its claw, lifting, or sliding sideways. Write down everyday tasks to test, like pressing a button or moving a block. A developer can then set up the 3D test world and give the program an access key from TypeSafe.
Once running, you can speak or type your goal to watch the robot pick one move at a time until it finishes. Remember that this experiment only works inside a simulated 3D space where exact object positions are already known. It cannot guide a physical robot arm or see through cameras.