What it does
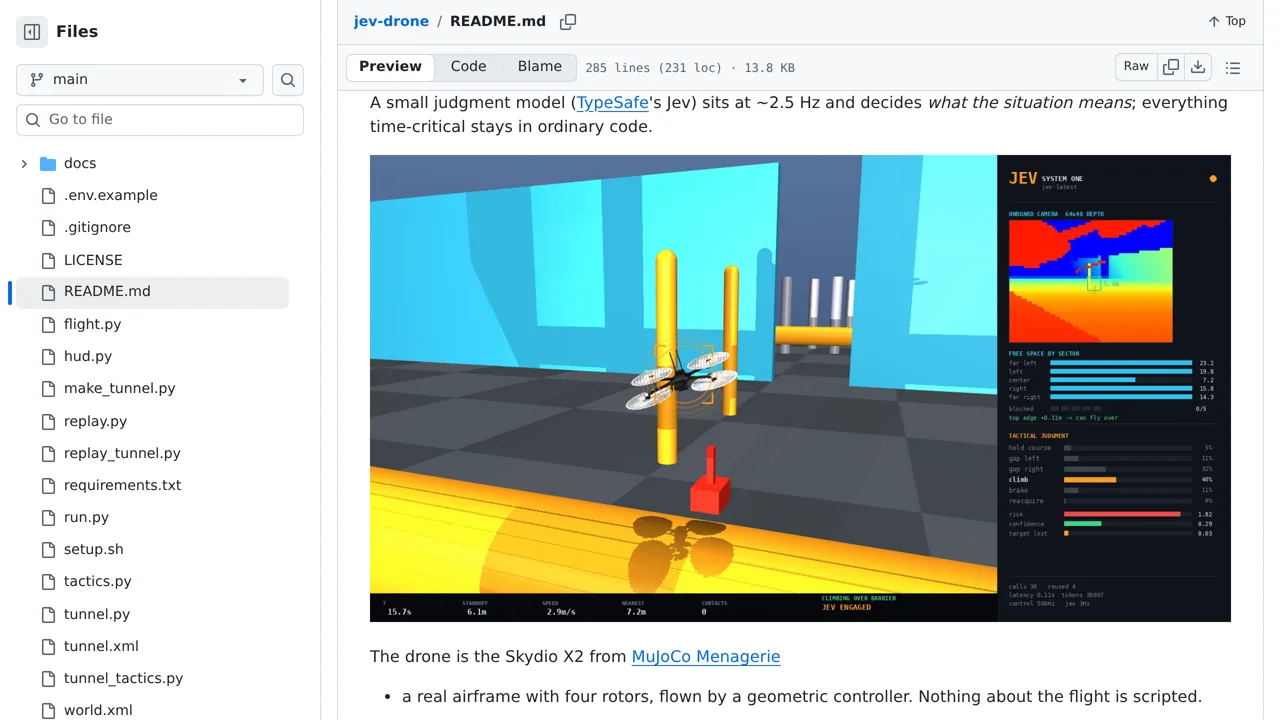
Jev pilots a MuJoCo drone by making a fresh flight decision from physics state on every tick.
Playable demos & bots
Only you can see your notes.
Screenshot unavailable. Open the experiment ↗
Jev pilots a MuJoCo drone by making a fresh flight decision from physics state on every tick.
Sketch out the flight moves you want a simulated craft to choose from, such as climbing, turning, or stopping. Have a developer turn camera pictures into simple numbers for obstacle heights and distances, then send those measurements to Jev to pick a move.
Your developer will need an account with TypeSafe to let your software talk to the model. The model cannot look at raw pictures directly, and fast safety code must always have the final say to stop crashes when things get too close.