What it does
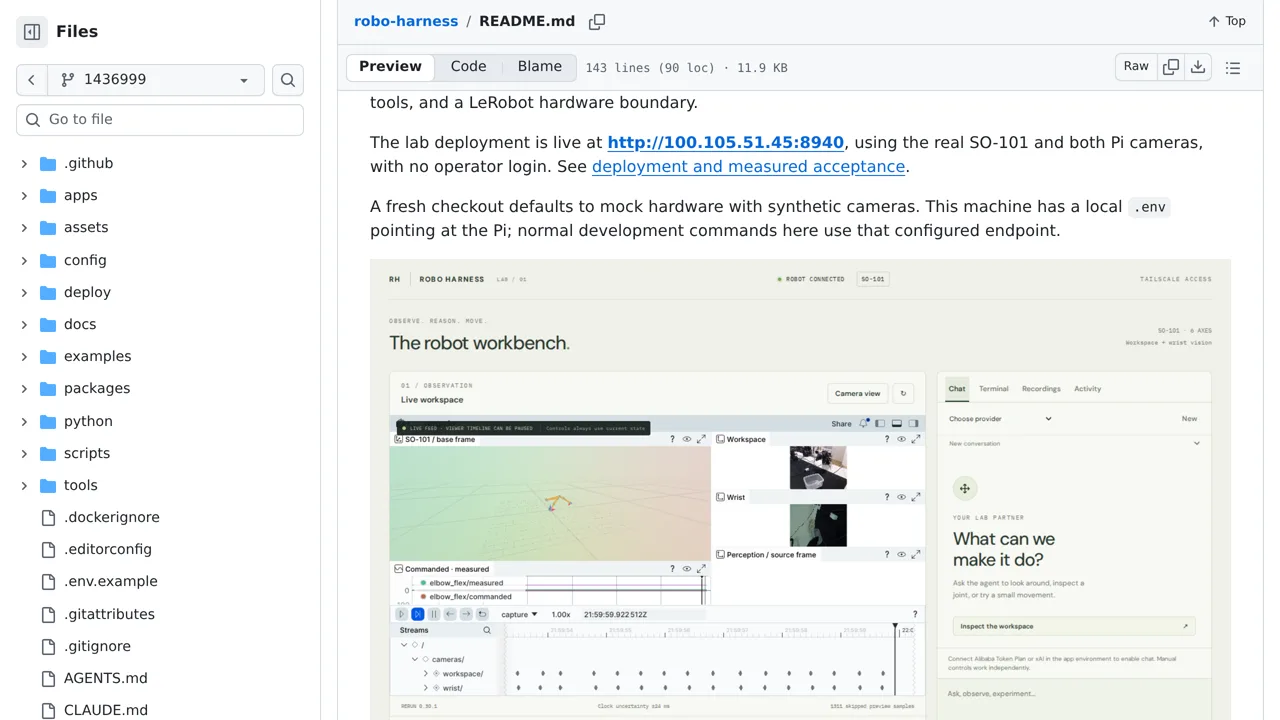
Fresh checkouts use explicit mock hardware and synthetic cameras unless a real LeRobot service is configured.
Agent tooling
Inspect and operate an SO-101 robot workbench where Jev can choose bounded joint movements.
Only you can see your notes.
Screenshot unavailable. Open the experiment ↗
Fresh checkouts use explicit mock hardware and synthetic cameras unless a real LeRobot service is configured.
Start by listing safe, small movements for your robot arm, such as turning a joint a few degrees. A developer can adapt this workbench setup so an AI model chooses only from your fixed list of motions, while checking that moves complete before starting the next one.
The system lets you safely test ideas using simulated hardware and cameras before connecting a real machine. Keep in mind that automated decisions cannot override human manual controls, and running an AI model requires provider credentials from your chosen service.