What it does
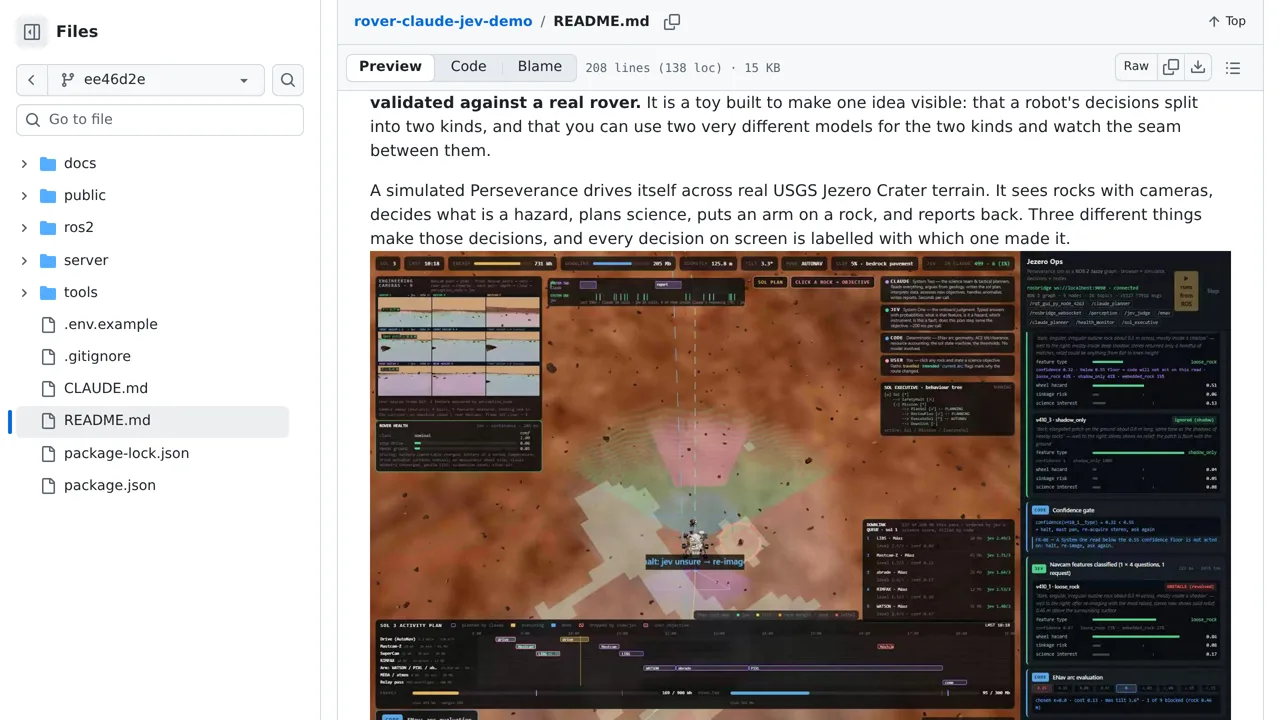
The simulation uses real Jezero terrain and exposes judgments through browser, ROS 2 and MCP interfaces; it is a demo, not flight software.
Playable demos & bots
A simulated Perseverance rover where Jev classifies terrain and hazards while Claude plans the mission.
Only you can see your notes.
Screenshot unavailable. Open the experiment ↗
The simulation uses real Jezero terrain and exposes judgments through browser, ROS 2 and MCP interfaces; it is a demo, not flight software.
You can sketch how a simulated vehicle or game robot divides its decisions. First, list quick safety checks, such as spotting steep rocks or sand traps. Next, list big planning tasks, like choosing a long science route. Describe your terrain hazards in plain words so a developer can assign each task to the proper tool.
A developer can borrow this method of separating instant checks from slower plans. Running the original project requires a TypeSafe account access key and a working Claude login. This software is only an educational toy simulation, so its hazard judgments cannot guarantee safety on a real machine.