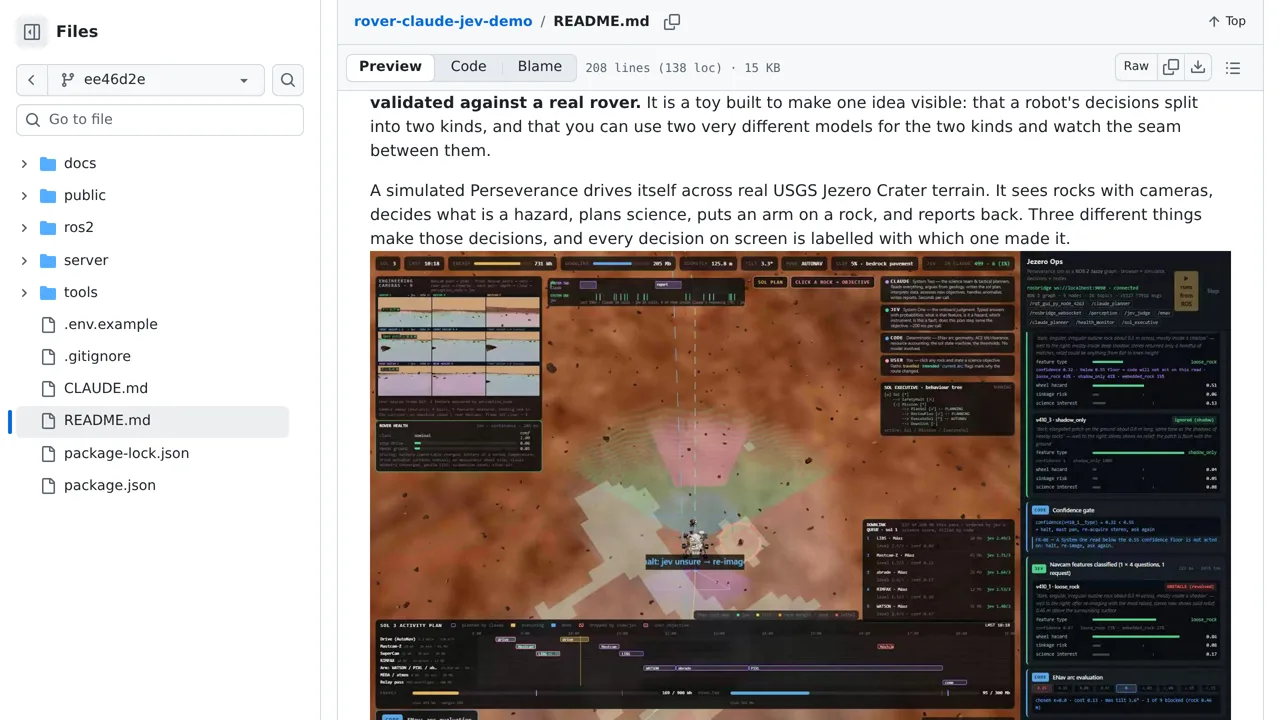
What it does
The simulation uses real Jezero terrain and exposes judgments through browser, ROS 2 and MCP interfaces; it is a demo, not flight software.
Maker-reported (not independently measured by JevMade): Jev answers in about 250 ms against 15–80 s for Claude (author-reported) · The MCP tool describes each Jev call as ~200–400 ms (author-reported)
- Primitives
- choice, noul, score
- Platform
- Node.js
- Added
- Project created
- GitHub stars
- 2 · snapshot 2026-09-22
Source checked 2026-09-22 — opened the primary source directly.