What it does
Built on Qwen-Drive, not hosted TypeSafe primitives, its main simulator tests wait for answers with emergency braking off. The interactive demo enables that braking by default; neither establishes road safety.
Benchmarks & research
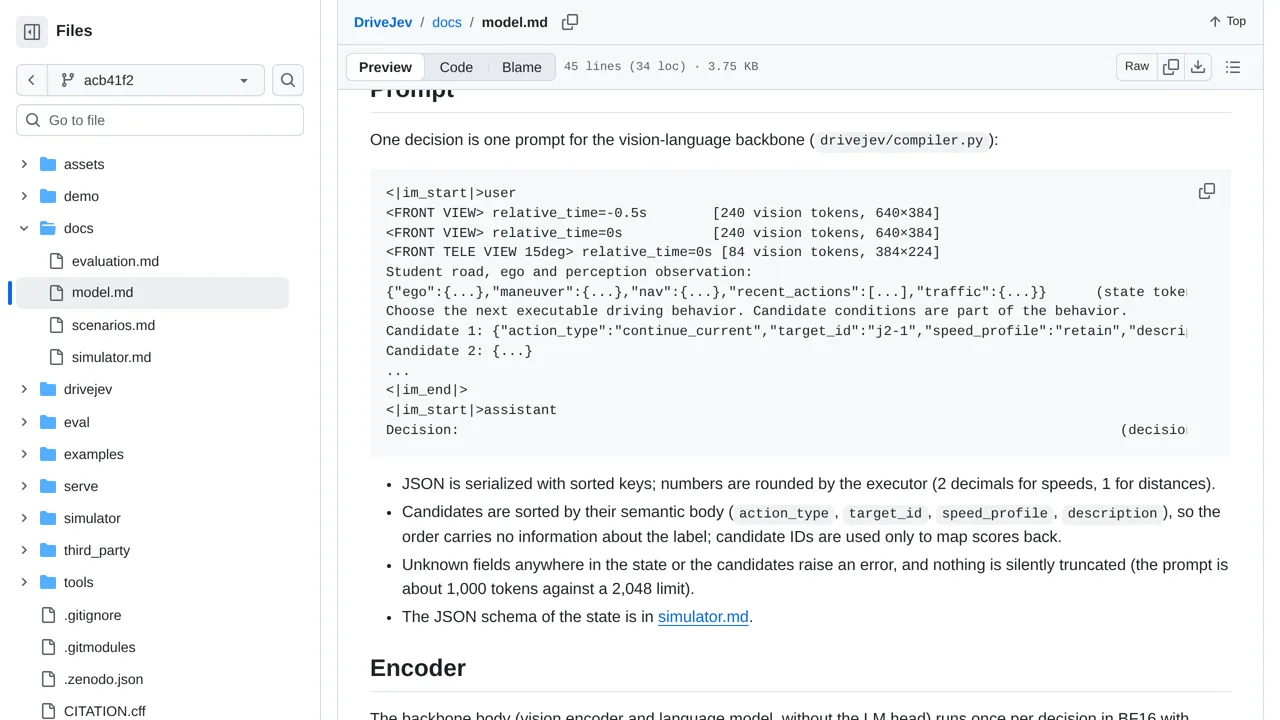
An independent visual driving model chooses among available behaviors in JevPilot, leaving local control code to turn each choice into steering and speed.
Only you can see your notes.
Screenshot unavailable. Open the experiment ↗
Built on Qwen-Drive, not hosted TypeSafe primitives, its main simulator tests wait for answers with emergency braking off. The interactive demo enables that braking by default; neither establishes road safety.
For a driving game, study how DriveJev separates choosing a move from carrying it out. AI looks at camera pictures and picks a move. Other code steers and sets speed. Start with the supplied examples to compare choices without building your own driving world.
A developer needs model files and suitable computer hardware to run it. Keep tests in the simulated world. Match the timing and emergency-braking settings: the main tests wait for answers, but the interactive demo uses different settings. Neither shows that a real car is safe.